Visualizing Mission Initiative for Rover Space Exploration
MSCD
Lydia Schweitzer
AdvisorsDaragh Byrne, Molly Steenson, William "Red" L. Whittaker, Richard Elphic
Abstract
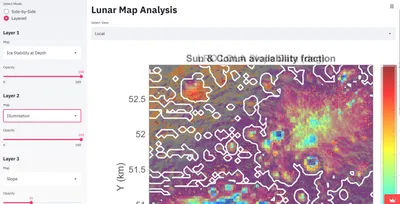
This thesis investigates how multi-dimensional, interactive visualizations can impact the development, operations, and exploration initiatives of unprecedented planetary rover missions, inquiring how such visualizations bring people on Earth closer to the experience of space. The context for exploring visualization methods and mission design is MoonRanger, a lunar micro-rover landing at the south pole of the Moon in 2022. This is unprecedented by way of its mechatronics, autonomy, destination and scientific purpose. There are three key values at the core -- visual decision making, mission planning, and scientific initiative. Research presents planning methodologies, technical development, and prototypes specific to this first-ever Commercial Autonomous Science (CAS) class of micro-rovers. The work discusses the prototyping experience, ideal planning interface capabilities, and mission operations design considerations for CAS missions. A resulting series of produced systems and prototypes are directly used within the context of MoonRanger’s mission. The thesis concludes with comments on a visual approach to space exploration and larger implications of the work.