Robust Visual Slam With Integrated Uwb Positioning For Construction Robotics
Publication Conference Paper2023

Robust Visual SLAM with Integrated UWB Positioning for Construction Robotics

Abstract

In this paper, we present a multimodal localization system for construction robotics operated in job sites where visual simultaneous localization and mapping (VSLAM) algorithms can yield inaccurate and inconsistent results due to environmental factors such as insufficient textures, occlusion, and unstable lighting conditions. The system integrates Ultra-Wideband (UWB) ranging and inertial measurement unit (IMU) with VSLAM as complementary sensing modalities. The integration of UWB and IMU can mitigate the cumulative drift of VSLAM and provide reliable localization when VSLAM fails. The fusion of multiple sensing modalities is based on the extended Kalman filtering (EKF) framework. We tested the localization system in real indoor environments with an industrial robot and validated it with ground truth data. The result shows that the proposed multimodal localization system achieves robust performance with increased accuracy under three test conditions ? inconsistent lighting, regions with minimal features, and regions with repetitive patterns.

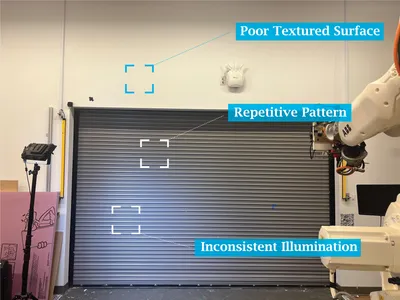
Fig. 1. Challenging scenarios on job sites for visual SLAM including (a) a vertical white wall surface without rich textures (b) a roller door with repetitive line patterns (c) areas with artificial lighting that may change over time.
How This Connects
Jingyang LiuJingyang LiuLinxiaoyi WanLinxiaoyi WanJoshua BardJoshua BardA Computational Framework For Robotic Quality Assessment and Management In ConstructionA Computational…Towards Adaptive Additive Manufacturing Image-based Monitoring for Binder Jet 3D Printing of Coarse Composite Concrete PowdersTowards Adaptiv…Proxemic-aware Augmented Reality For Human-Robot InteractionProxemic-aware …Towards Adaptive Additive Manufacturing with Semi-autonomous Robotic Binder Jet 3D Printing of ConcreteTowards Adaptiv…Computational design and fabrication of highly customizable architectural space frames: Making a flat-cut Weaire-Phelan structureComputational d…
Robust Visual SLAM with Integrated UWB Positioning for Construction Robotics
Open in Constellation View