Sequencing optimization of stability-aware robotic assembly for discrete frame structures
Abstract
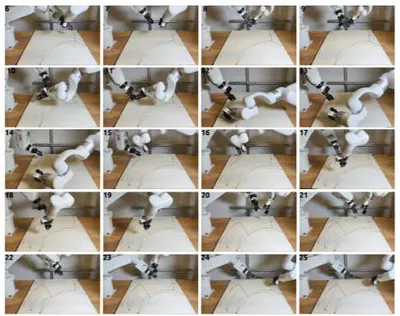
This research paper investigates a stability-aware robotic assembly process for discrete frame structures. The approach generates sequencing for robot target assignment that provides temporal support for stabilizing the structure during construction, thereby enabling scaffold-free assembly. We integrated iterative finite element analysis to greedy search for optimal assembly sequences by: 1) assuming a temporary rigid support by robot at its current assembly location; 2) finding the next component that results in the minimal average displacements across members of the in-progress structure through greedy search; and 3) introducing penalties to re-rank low average displacement options that contain significant displacement outliers. This digitally simulated sequence-finding pipeline minimizes displacement throughout the assembly process of long-span, free-form, linear element structures joined by rigid connections. The result establishes a high-level foundation for target-sequential assignment in robotic assembly. The proposed method is generalizable to discrete frame structures, as demonstrated in this paper through case studies of funicular shell structures with a multi-robot step-up.
More by these authors