Towards A Distributed Robotically Assisted Construction Framework
Publication Conference Paper2020

Towards a Distributed, Robotically Assisted Construction Framework

Abstract

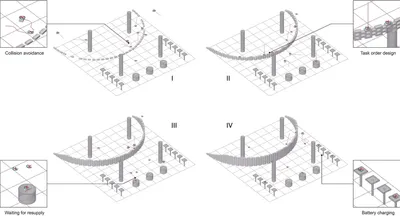
In this paper we document progress towards an architectural framework for adaptive and distributed robotically assisted construction. Drawing from state-of-the-art reinforcement learning techniques, our framework allows for a variable number of robots to adaptively execute simple construction tasks. The paper describes the framework, demonstrates its potential through simulations of pick-and-place and spray-coating construction tasks conducted by a fleet of drones, and outlines a proof-of-concept experiment. With these elements the paper contributes to current research in architectural and construction robotics, particularly to efforts towards more adaptive and hybrid human-machine construction ecosystems. The code is available at: https://github-com.cmu.idm.oclc.org/c0deLab/RAiC

Four snapshots from the brick laying simulation. A video of the entire simulation can be seen in Computational Design Lab (2020).
How This Connects
Zhihao FangZhihao FangYuning WuYuning WuArdavan BidgoliArdavan BidgoliDaniel Cardoso LlachDaniel Cardoso …Robot in the loop: a human-centered approach to contextualizing AI and robotics in constructionRobot in the lo…Towards Human-Centered Construction Robotics: A Reinforcement Learning-Driven Companion Robot for Contextually Assisting Carpentry WorkersTowards Human-C…Robot in the loop: a human-centered approach to contextualizing AI and robotics in constructionRobot in the lo…Towards Human-Centered Construction Robotics: A Reinforcement Learning-Driven Companion Robot for Contextually Assisting Carpentry WorkersTowards Human-C…
Towards a Distributed, Robotically Assisted Construction Framework
Open in Constellation View