Robotic Technologies and the Reconfiguration of Building Construction Work
PhD-CD
Abstract
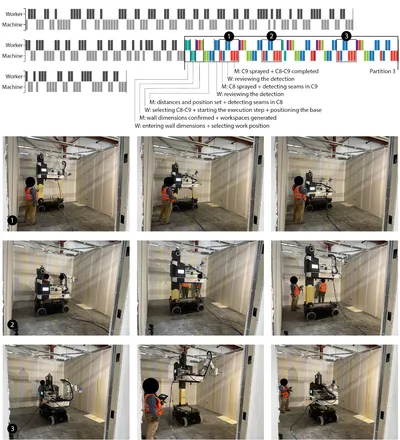
Advancements in robotics have led to the exploration of industrial arms, mobile robots, drones, and other semi-autonomous technologies in building construction. Drawing from primary historical and ethnographic research, this dissertation contributes a historically and socially grounded understanding of the field of construction robotics. It especially examines how technology designers conceptualize construction work in robotics practices, identifying a shift from high-level descriptions and classifications of construction tasks in the 1980s to situated engagements with workers and construction knowledge in the present. Revealing contrasts between early visions of automation and productivity with emergent approaches seeking adaptive robot support and worker–robot work-sharing, it traces the emergence of alternative systems, new skills, and kinds of interdisciplinary technical labor. Drawing from these findings, the dissertation develops three arguments. First, that technology designers’ conceptions of work decisively shape system development in construction robotics. Second, that the participation of designers and workers in each other’s knowledge worlds helps to conceive alternative systems and practically integrate robotic technologies into existing workflows. Lastly, that automation progresses faster in designers’ discourses than in machines. From here, the dissertation outlines new considerations and pedagogies across computational design, human-computer interaction, robotics, and architecture for the sensible integration of these technologies in construction.
More by these authors