Responsive Robotic Assembly with Heterogeneous Raw Wood
MSCD
Abstract
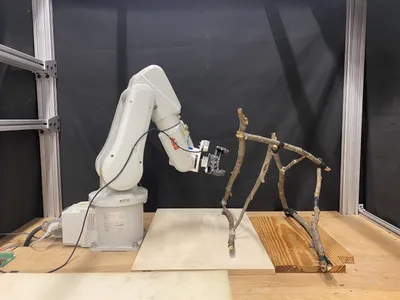
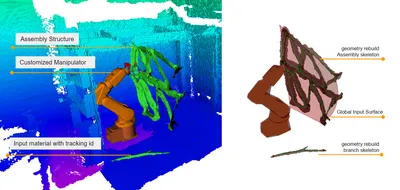
This thesis reviews the state of art in architectural robotic fabrication, and develops a bi-system framework for responsive assembly with non-standardized raw branches, creating potentials for automation in mass customized fabrication with heterogenous natural materials. The framework synthesizes features of adaptive path planning, material analysis, and parametric design as an efficient and dynamic feedback system to adjust decision-making both on the trajectory planning side and design decision side. Through extensive testing and research, the thesis completed a series of prototypes to verify, improve and evaluate the performance of the system. Apart from prototypes, the results also include a branch-specific design strategy for global shape fitting, a material analysis strategy to quantify and make hierarchical categorization, and optimization for the pick and place procedure in a complicated context. It demonstrates the future potential of robotic automation to directly engage non-standardized natural materials in the field of architectural manufacture and construction.
More by these authors